·2 min read
Nexus Tactical: Autonomous Color-Tracking Exploration Robot with ESP32-CAM & Mecanum Drive
Dual ESP32 architecture, OpenCV autonomous color tracking, Pan-Tilt camera unit with laser targeting, 4-way ultrasonic distance and gas sensing — building Nexus Tactical.
Paper
MEKON'26 · Student Conference on Mechatronics
“Çoklu Sensör Entegrasyonu ve Görüntü İşleme Destekli Hedef Takibi Yapan Çok Amaçlı Keşif Robotu”
25–26 June 2026 · Istanbul Gelişim University · Association of Mechatronics Engineers
Presented as a paper; to be published in the MEKON proceedings book.
Mission specs
- Brains
- Dual ESP32: DevKit v1 + ESP32-CAM
- Link
- Two-way ESP-NOW + Wi-Fi access point
- Drive
- 4 DC motors, mecanum wheels, 2× TB6612FNG
- Vision
- OV2640 camera, pan-tilt, OpenCV colour tracking
- Sensors
- 4× HC-SR04, MQ-9 gas, PIR, DHT11
- Interface
- Browser control panel, no app needed
Mission log
Every change to the project is logged here with its date, newest first.
- Site
Project page refreshed with build photos, this mission log and the MEKON'26 paper. Nexus now also patrols the Ring Corridor in SMT-22.
- Release
Technical write-up and drive, pan-tilt and colour-tracking demo videos published.
- Conference
Paper presented at MEKON'26: "A multi-purpose scouting robot with multi-sensor integration and vision-assisted target tracking". It will appear in the MEKON proceedings.
- Interface
Control panel gained a Matrix theme, a non-blocking gas alarm and a servo D-pad.
Image records
In the field
Build log
Control panel
Video records
Next steps
- ROS 2 integration
- LiDAR-based SLAM mapping
Technical report
Architecture, hardware and software in detail.
Introduction: Autonomous Exploration & Holonomic Mobility
One of the primary challenges in mobile robotics is achieving high maneuverability in tight quarters while processing environmental telemetry and executing computer vision decisions in real time. Nexus Tactical was engineered to address this challenge by fusing Mecanum omnidirectional holonomic drive, a dual ESP32 microcontroller architecture, OpenCV-driven target tracking, and a rich multi-sensor array into a unified exploration vehicle.
The robot broadcasts its own Wi-Fi Access Point, eliminating the need for an external router or internet connectivity.
🚀 Key Features
- 🔄 Mecanum Holonomic Drive: 4 independent DC gearmotors with Mecanum wheels providing 11 movement directions (strafing, 45° diagonals, 360° spot rotation).
- 📷 Live Video Stream & Pan-Tilt: High-speed MJPEG video streaming via ESP32-CAM (OV2640) on a 2-axis SG90 servo pan-tilt platform.
- 🎯 OpenCV Autonomous Tracking: Color conversion (BGR ➔ HSV), contour detection, and closed-loop PID servo tracking on the client machine.
- 🔴 Laser Targeting & 1W LED: Concentrated laser diode aligned with the optical axis for target designation, accompanied by a 140-lumen spotlight LED.
- 📏 4-Way Ultrasonic Sensing: HC-SR04 ultrasonic distance sensors on front, rear, left, and right flanks for autonomous collision avoidance.
- 💨 Environmental Sensors: MQ-9 sensor for carbon monoxide/combustible gas monitoring, PIR motion detection, and DHT11 ambient temperature/humidity.
🖥️ Glassmorphism Web Control Dashboard (Terminal UI)
The custom-designed web interface elevates driver experience by rendering telemetry gauges and autonomous target modes in real time:
- Manual drive & telemetry: joystick mecanum driving, speed control and live sensor readings.
- Autonomous target & colour tracking: pick a red, blue or yellow target and the camera and robot follow it on their own.
- Critical gas alert: when the MQ-9 crosses its threshold the panel raises a full-screen alarm without stopping the drive.
🏗️ System Architecture & Hardware Diagrams
Nexus Tactical uses a segregated dual-microcontroller architecture:
- Main Controller (ESP32 DevKit v1): Runs the core web server, drives motor H-bridges (dual TB6612FNG) and PCA9685 I2C PWM controller, and samples telemetry from 4x HC-SR04, MQ-9 gas, PIR, and DHT11.
- Camera & Optical Module (ESP32-CAM OV2640): Handles MJPEG video streaming and controls laser/LED outputs. Frames are processed on the client host using OpenCV, sending PID servo correction values back via REST API.
Hardware Interconnection Diagram
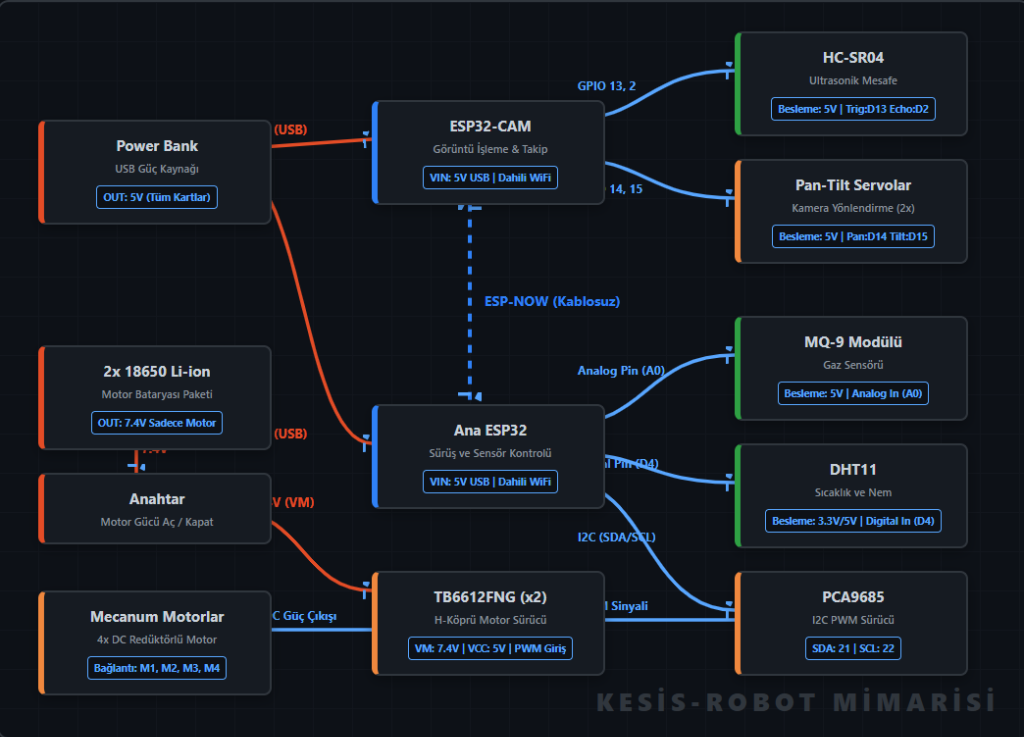 Nexus Tactical Hardware Architecture Diagram
Software & Wireless Bridge Architecture
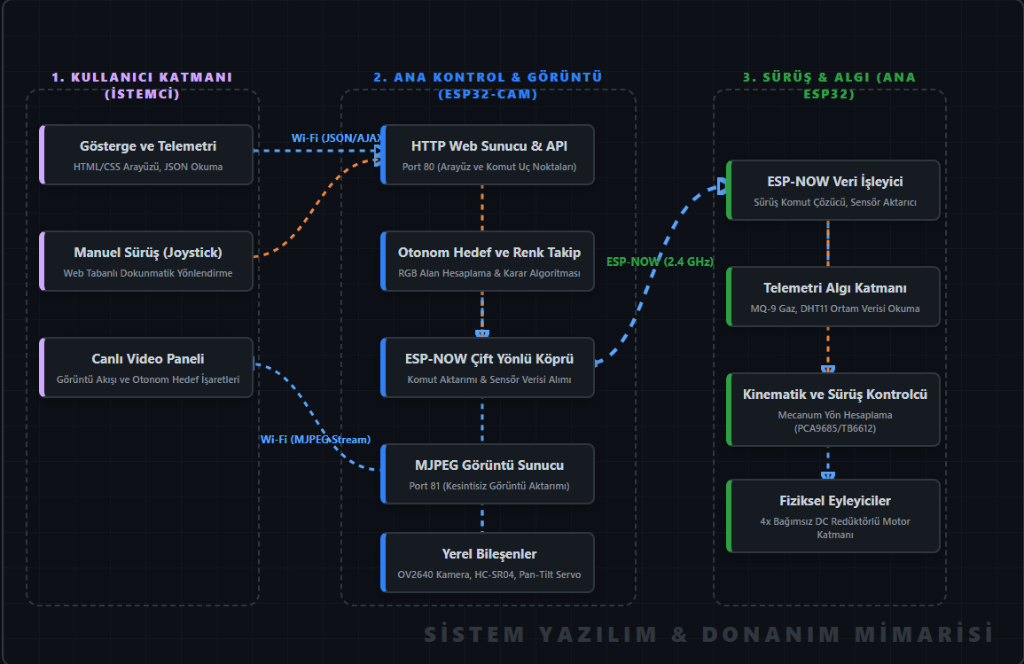 Nexus Tactical Software Flow & ESP-NOW Dual Bridge
🎯 Conclusion
Nexus Tactical brought embedded systems, robot kinematics, computer vision and web-based remote control together on one platform. Our paper on its multi-sensor integration and vision-assisted target tracking was presented at MEKON'26. Ongoing changes are tracked in the mission log at the top of this page.